01
The problem
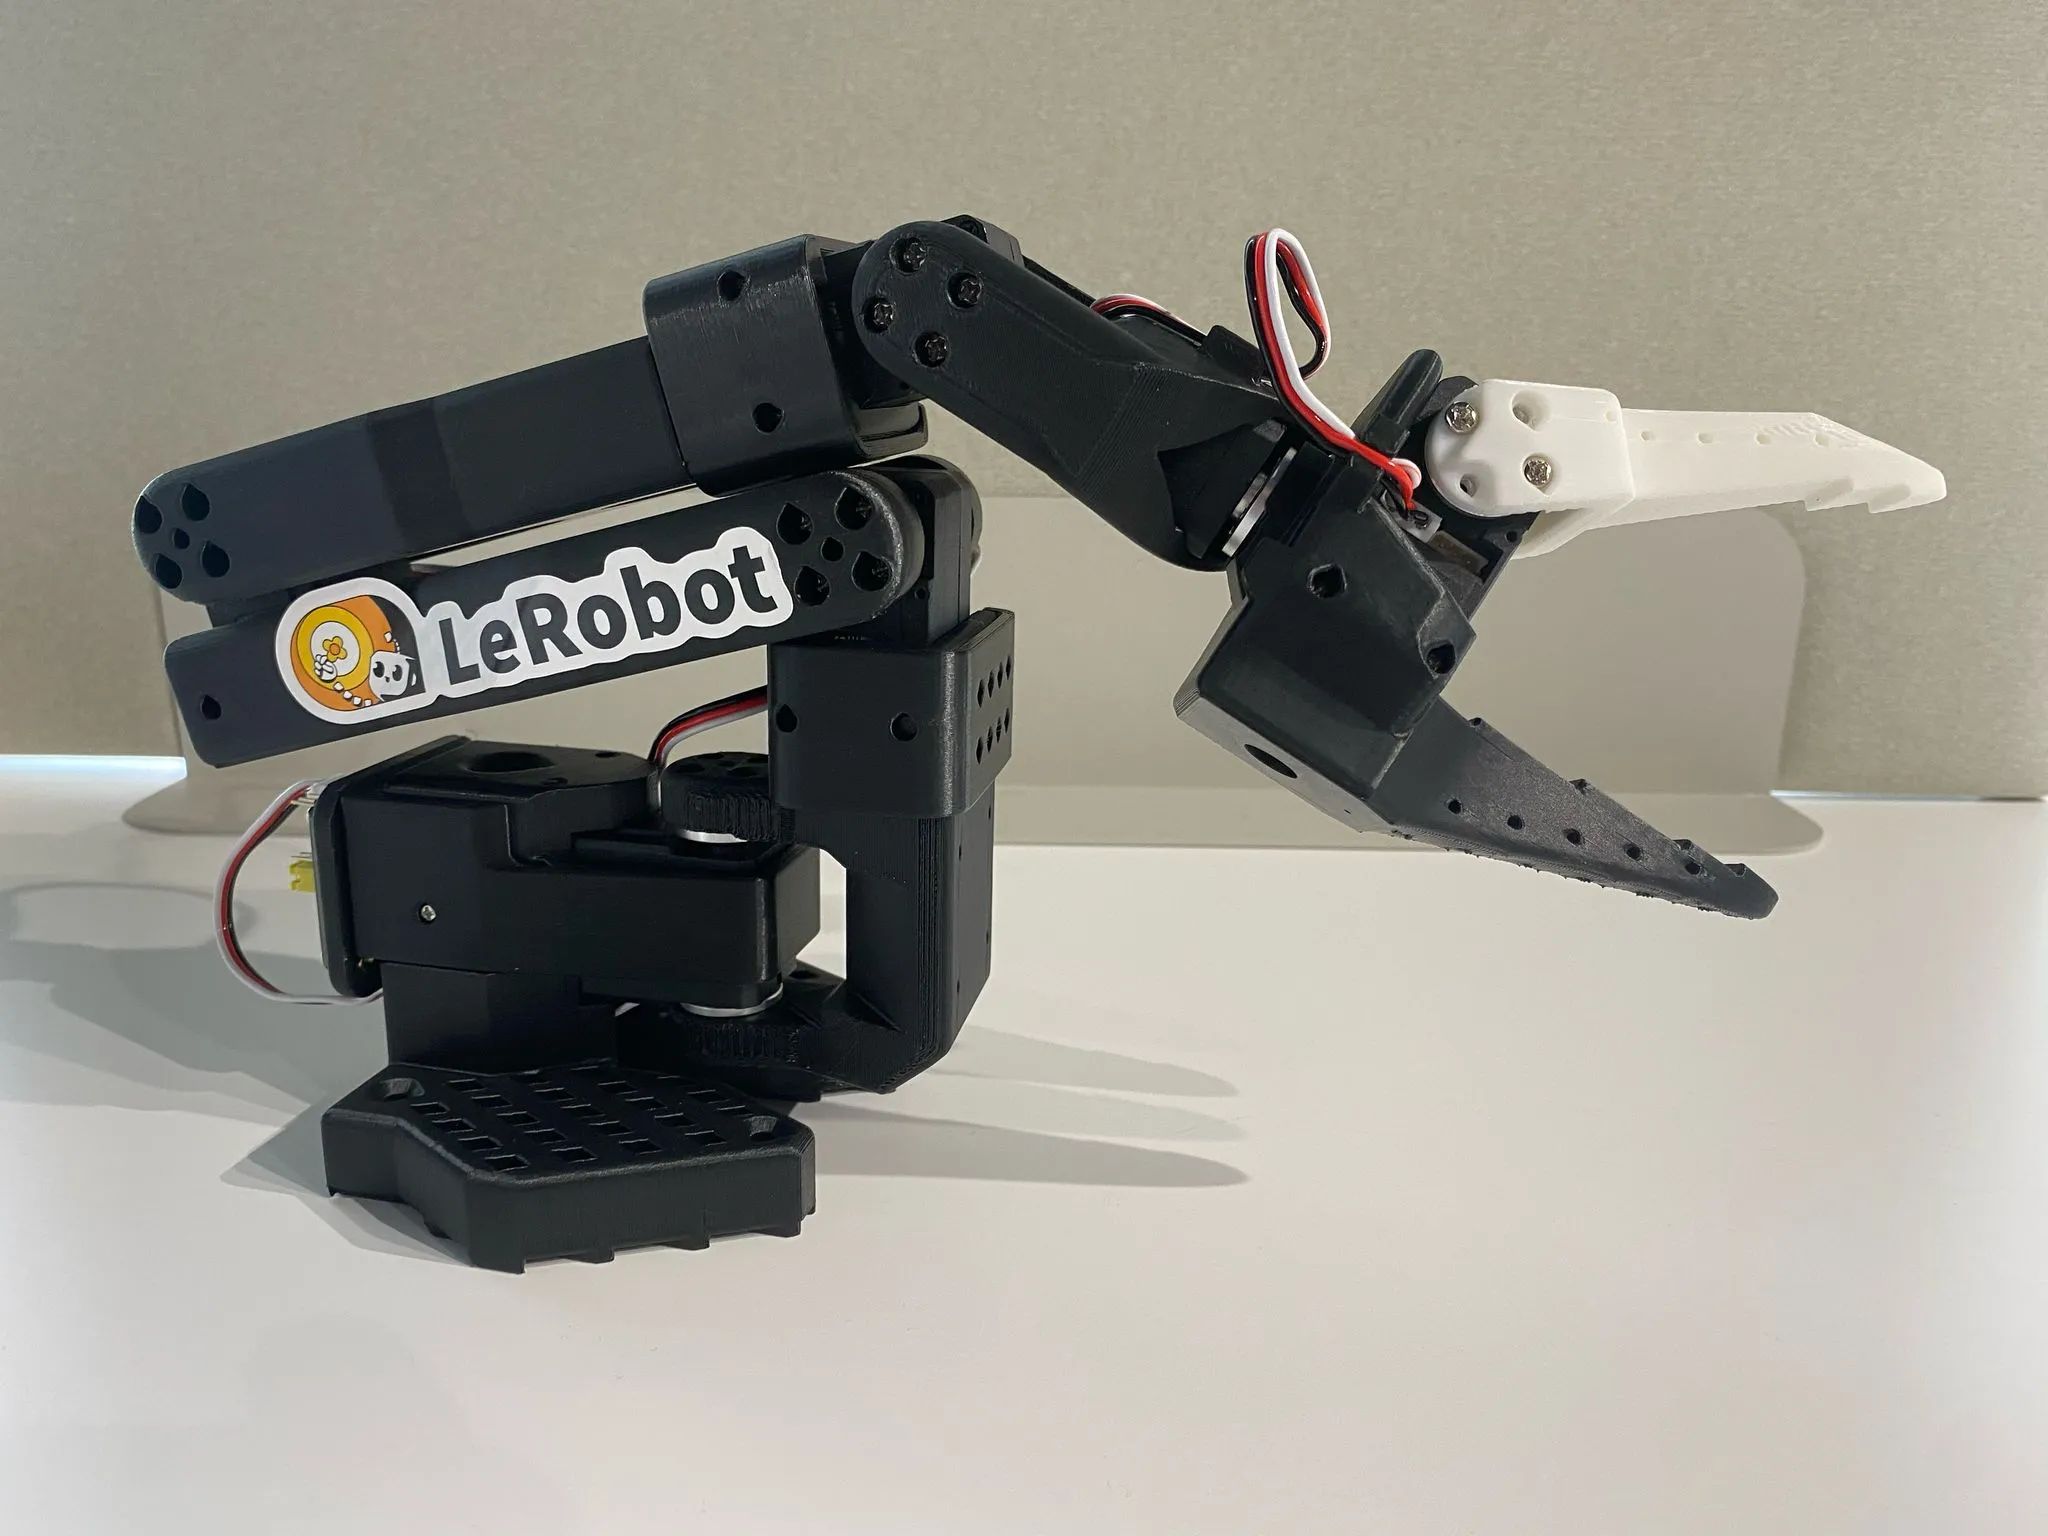
Can a world model trained on real robotics episodes provide useful representations for arm control? I explored this hypothesis with LeWM on a DROID 10k subset, focusing on generalization limits.
02
My role
I prepared the DROID 10k subset data and ran LeWM training experiments.
03
Architecture & pipeline
- Train LeWM on the DROID 10k subset.
- Explore its use for robot-arm control.
04
Results & limitations
The experiment did not achieve the robot-arm control objective. Training on this subset does not demonstrate usable control.
The protocol and observations still need documentation to distinguish possible causes of failure; no generalization performance is claimed here.
05
Next iterations
Document the protocol and observed limitations. R&D is then moving toward 3D representations and LiDAR point clouds to explore state prediction in real environments.